NSF30
Uses EtherCAT bus to control the servo motor for higher control accuracy
Compatible with pulse control, allowing flexible selection of the appropriate control method according to on-site conditions
Optimizes force closed-loop control to improve force control accuracy of the electric cylinder at high speed
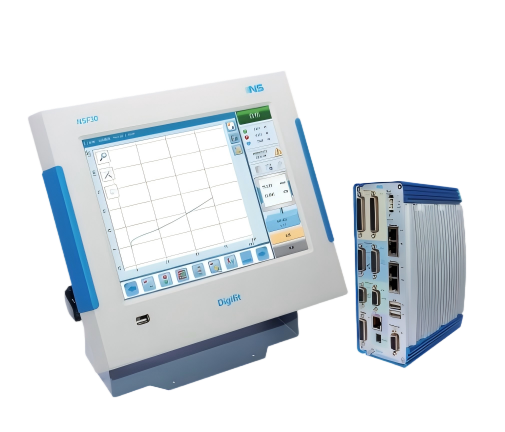
| Technical Specifications | Model | NSF30 | |||||||||
| Number of Measurement Channels | 1X/Ychannel | ||||||||||
| Resolution/Channel | Bit | 24 | |||||||||
| Max. XY Sampling Rate | kHz | 10 | |||||||||
| Control Mode | EtherCATbus communication control, pulse control | ||||||||||
| Sensor | supportsupportDisplacement Channel | busencoder, potentiometer, Voltage±10V, incremental square wave(ABZsignal) | |||||||||
| supportsupportPressure Channel | Strain-Gauge Sensor, Voltage±10V | ||||||||||
| Measurement Function | Y(X), Y(t), X(t) | ||||||||||
| Evaluation Objects (EOs) | Type | UNI-BOX(Window), ENVELOPE(Envelope), LINE(X+Y), CALC INFFLECTION,NO-PASS ,HYSTERESIS(X + Y) | |||||||||
| Evaluation Result Output | DIGOutput Fieldbus Optical | OK, NOK OK, NOK, Process Value Curve, Process Value, Trend Display, Signal Light | |||||||||
| PC Software | MNS | passedMNSPC Software, maximumconnection255units, same screen16units | |||||||||
| Data Output Format | USB Ethernet (TCP/IP) | CSV | |||||||||
| Features | Simple installation method, saving on-site commissioning time | ||||||||||
| Data Output | Interface | PROFINET(optional), EtherNet TCP/IP, USB, Modbus TCP | |||||||||
| Data Storage | 28G+external expansion512G | ||||||||||

 Instruments and Intelligent Control